Hackaday · Creativity & design
Robot Hand Learns to Walk Using Fingers as Legs
Researchers have developed a robotic hand that can walk using its fingers as legs, enabling it to traverse various terrains and manipulate objects.
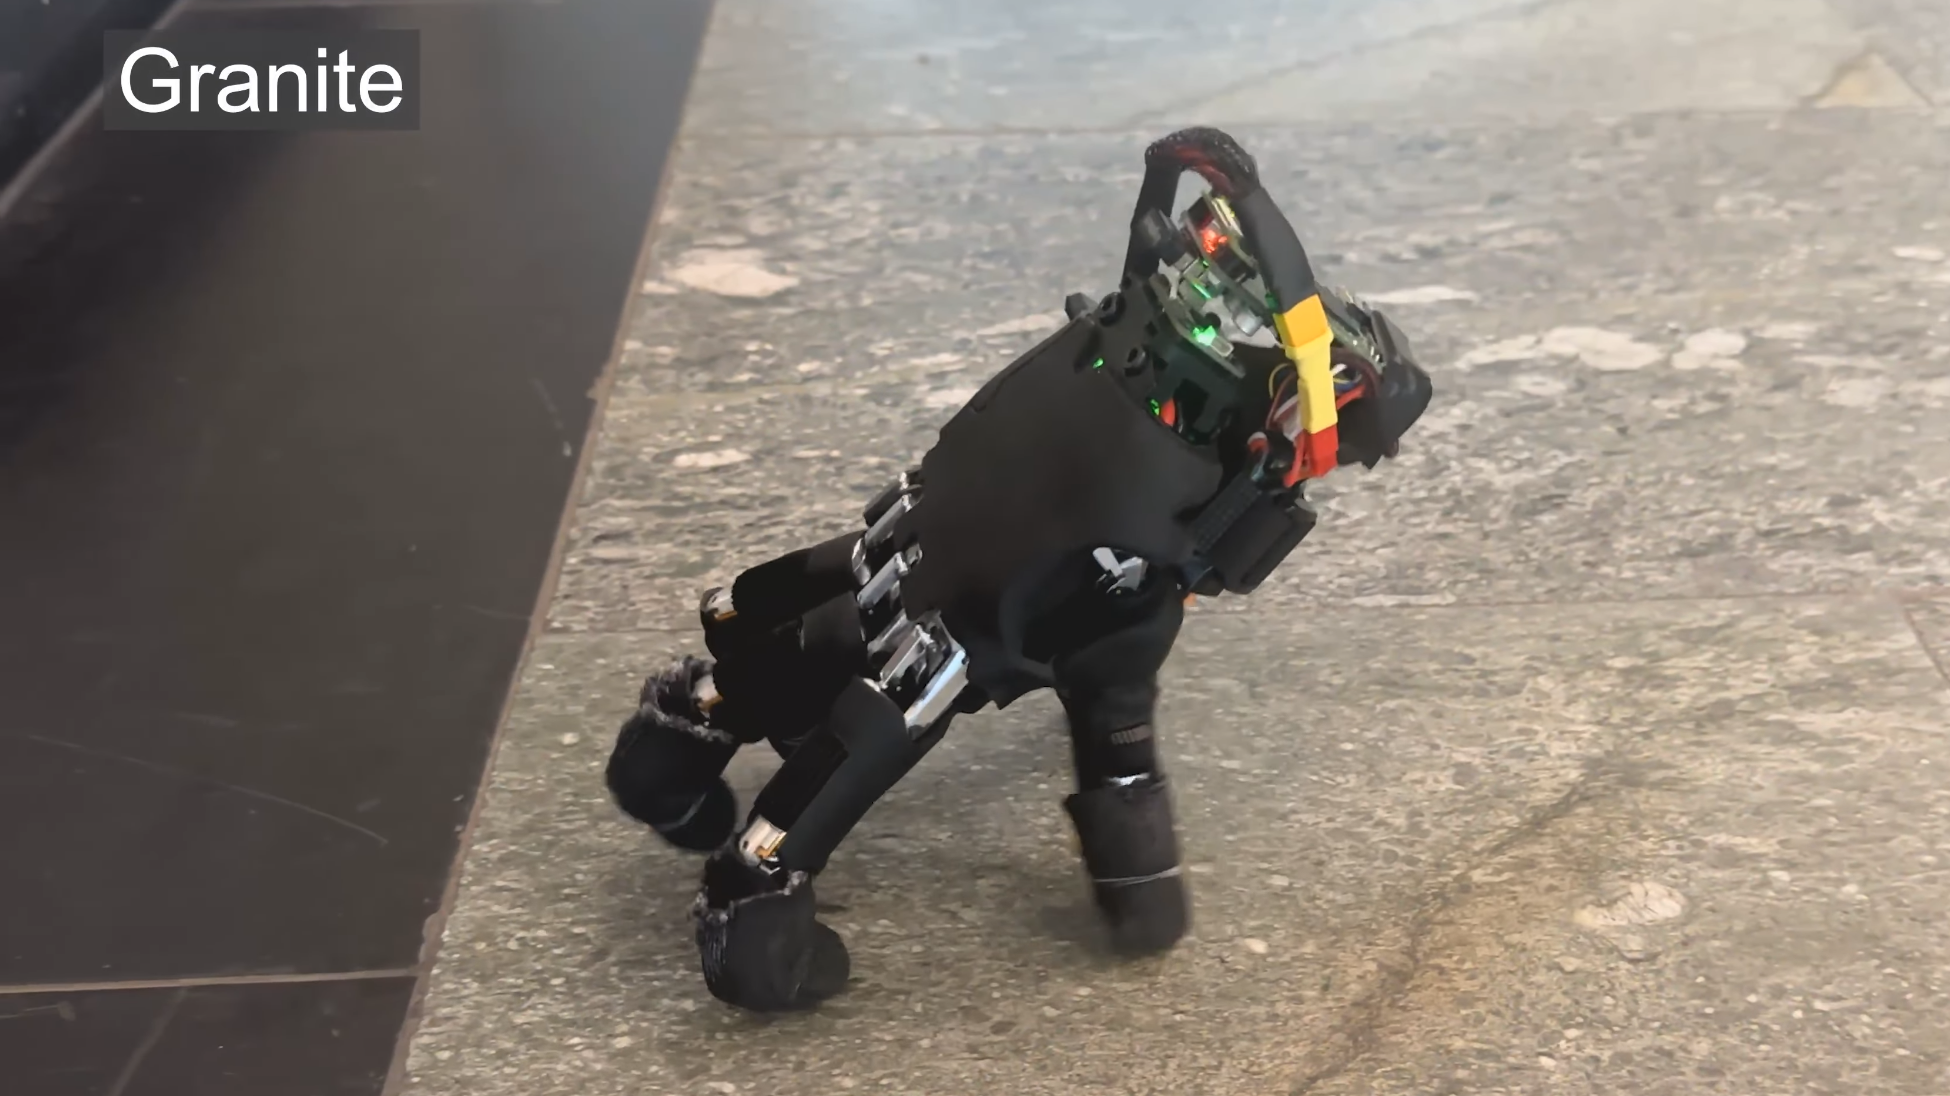
The hand, based on a commercial model and enhanced with a Raspberry Pi and battery, uses a neural network to control its twenty joints. This network iteratively determines the next joint state based on past movements, the hand's current condition, and its objective.
Training involved a simulated model and reinforcement learning, which resulted in faster locomotion than a quadrupedal motion model. The hand was trained to walk straight, turn, recover from falls, and press keyboard keys, though it lacks a camera for independent keyboard operation.
The hand demonstrated impressive fall recovery, righting itself in 21 out of 25 attempts within twenty seconds. However, its geometry causes it to drift rightward, requiring constant correction.
It successfully navigated fourteen different surfaces, from rubber mats to gravel and grass, and could push light objects towards designated goals.
The researchers suggest this technology could grant greater mobility to larger robots, allowing a hand to detach and walk to distant locations.
The project's accessibility means it is within reach for hobbyists and hackers.
AI-samenvatting op basis van de bron.
Hackaday