Hackaday · Creativity & design
Pogo-Bot Navigates All Terrain With Compliant Foot
Engineers have developed a monopedal hopping robot that utilizes a unique foot design to maintain stability on varied surfaces.
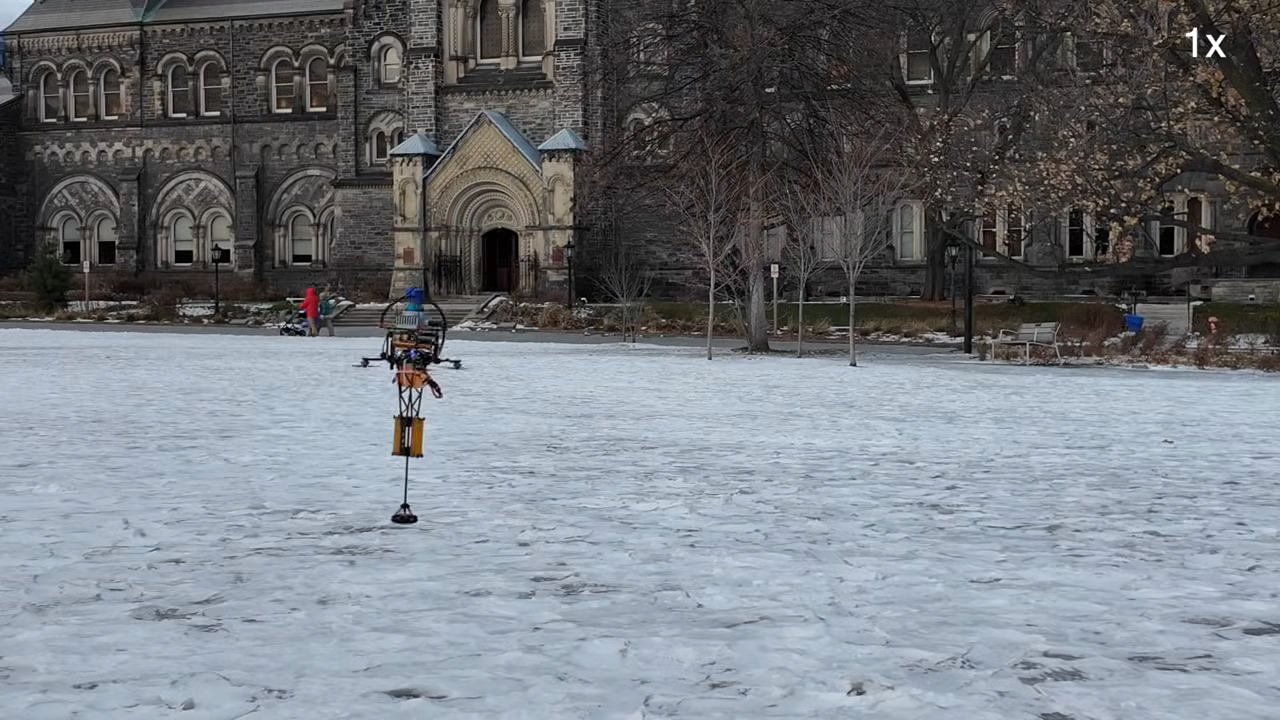
The robot, a creation of University of Toronto students, combines elements of a pogo stick and a quadcopter. Its hopping mechanism relies on a spring-loaded, single-legged landing gear with a spikey, pivoting foot pad.
Elastic bands tension the foot pad, allowing it to adapt to different terrains, from soft sand to hard ice. The quadcopter's propellers provide thrust for movement, while the leg enables hopping.
Initial designs with a simple spike failed, but the addition of a foot with traction and pivoting capabilities improved performance significantly. This allows the robot to overcome obstacles and maintain balance on slippery surfaces.
While other one-legged robots exist, this quadcopter variant is notable for its ability to operate in challenging winter conditions.
AI-samenvatting op basis van de bron.
Hackaday