designboom · Creativity & design
Robotic Hand Learns to Walk on Its Fingertips
Researchers at ETH Zurich have developed an autonomous five-fingered robotic hand capable of walking, steering, and interacting with objects using only its fingers.
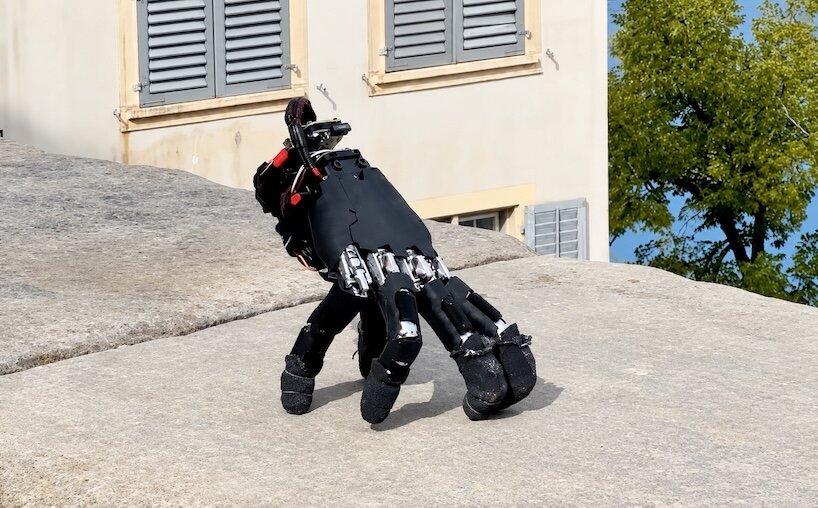
The prototype, based on a commercial anthropomorphic hand with 20 actuated joints, has been equipped with an onboard system including a battery, sensors, and computing hardware, making it an untethered robot weighing 818 grams. This design allows the hand to function as a mobile robot, with fingers alternating between supporting, moving, and manipulating its body.
To overcome the asymmetry of the five fingers, researchers employed reinforcement learning, training locomotion policies in simulation before transferring them to the physical hand. This enabled the robot to move across various indoor and outdoor surfaces, including carpet, tile, asphalt, grass, and stone.
The hand demonstrated an ability to recover from falls, successfully righting itself in most trials when placed on its side. It can also transition from locomotion to manipulation, supporting itself while pressing keyboard keys and completing tasks in the puzzle game Sokoban.
Further experiments showed the hand approaching and pushing objects, highlighting the integration of locomotion and manipulation within a single system. This approach aims to reduce the need for external arms or larger mobile platforms.
The researchers envision future applications where a robot could deploy the hand into narrow or confined spaces for independent operation. Future development will focus on enhancing onboard perception and movement capabilities.
AI-samenvatting op basis van de bron.
designboom